

electric motor
-
What is an electric motor?
An electric motor is a device that transforms electrical energy into mechanical energy, often through electromagnetic phenomena. Michael Faraday demonstrated in the 1820s and 30s that sending an electric current through a wire coil between a magnet's poles would cause the coil to turn. This principle became the basis for the electric motor.
Electric motors create mechanical torque through the interaction of conductors carrying current at right angles to a magnetic field. They have found widespread use, including driving barn machinery, chaffcutters, root cutters, and water pumps, because of their ease of use and low maintenance.
3 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
How does an electric motor work?
An electric motor transforms electrical energy into mechanical energy, typically using electromagnetic phenomena. Most electric motors generate mechanical torque through the interaction of conductors carrying current within a magnetic field.
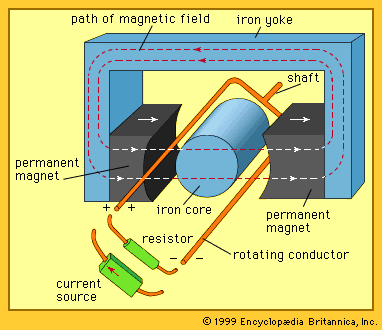
In a direct-current (DC) motor, a stationary magnetic field, created by poles on the stator, is produced across the rotor. When a direct-current supply connects to the armature terminals, the current interacts with the magnetic flux, generating torque and accelerating the rotor. Practical DC motors contain multiple coils that contribute to torque production.
2 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
What are the main parts of an electric motor?
An electric motor typically consists of a stator, which remains stationary, and a rotor, which rotates to produce torque. The stator creates a magnetic field using field coils or permanent magnets. The rotor, also known as the armature, includes an iron core and a coil accommodated in slots. In induction motors, the rotor has conductors connected by end rings. Other essential components include graphite brushes, which connect to the commutator switch on the rotor shaft, and the motor terminals, which connect to the power supply.
1 Britannica SourceCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
How does electricity make an electric motor spin?
Electric motors convert electrical energy into mechanical energy using electromagnetism.
Here's how electricity makes an electric motor spin:
- A current flows through the motor's wires, generating a magnetic field.
- This magnetic field interacts with the magnetic field of permanent magnets (or electromagnets) within the motor.
- The interaction produces a force, or torque, that causes the rotor to spin.
- A commutator reverses the current's direction, maintaining continuous torque and rotation.
- The motor's speed is proportional to the voltage of the power source.
3 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
What are the different types of electric motors?
Electric motors convert electrical energy into mechanical energy, typically through electromagnetic phenomena.
Different types of electric motors include:
* DC commutator motors Use a direct-current supply connected to the armature terminals to generate torque and accelerate the rotor. Adjustable field current motors are known as shunt motors or separately excited motors.
* Series motors Field coils carry the same current as the armature. High current produces high torque and low speed, while reduced current decreases torque and increases speed.
* Servomotors Small induction motors with two stator windings, used to provide controlled torque. The motor torque is approximately proportional to the voltage on the second winding and thus to the signal input.
* Stepper motors Motors that rotate in small steps rather than continuously.2 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
Where are electric motors used in everyday life?
Electric motors are workhorses that convert electrical energy into mechanical energy using electromagnetic phenomena. They are integral to daily life, found in many devices that save labor and time.
Examples:
* Home appliances Electric motors power numerous home appliances such as sewing machines, razors, toothbrushes, and hair dryers.
* HVAC systems HVAC (heating, ventilation, and air conditioning) systems use electric motors to control temperature, humidity, and air movement in buildings. Fans driven by electric motors bring in fresh air and vent old air.
* Power tools Many power tools use electric motors. The most popular ones are electric drills and circular saws.
* Electric locomotives Electric locomotives utilize electric traction, considered economical and efficient for railroads when cheap electricity is available.5 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles.
electric motor, any of a class of devices that convert electrical energy to mechanical energy, usually by employing electromagnetic phenomena.
Most electric motors develop their mechanical torque by the interaction of conductors carrying current in a direction at right angles to a magnetic field. The various types of electric motor differ in the ways in which the conductors and the field are arranged and also in the control that can be exercised over mechanical output torque, speed, and position. Most of the major kinds are delineated below.
Induction motors
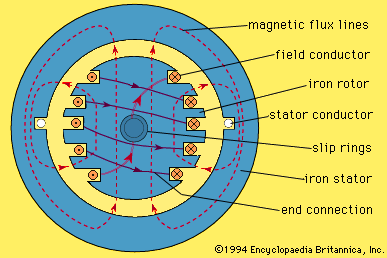
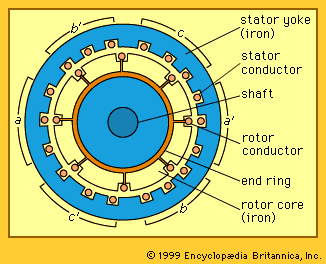
The simplest type of induction motor is shown in cross section in the . A three-phase set of stator windings is inserted in slots in the stator iron. These windings may be connected either in a wye configuration, normally without external connection to the neutral point, or in a delta configuration. The rotor consists of a cylindrical iron core with conductors placed in slots around the surface. In the most usual form, these rotor conductors are connected together at each end of the rotor by a conducting end ring.



 " height="20" alt="HEW Logo">
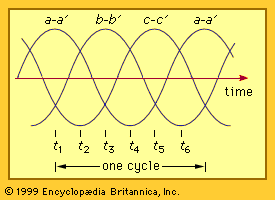
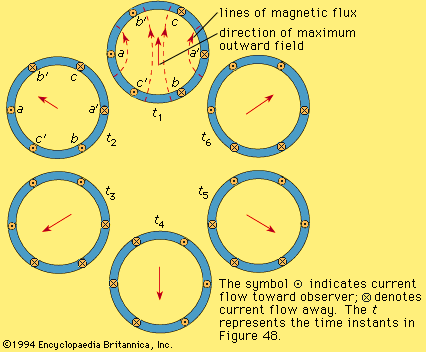
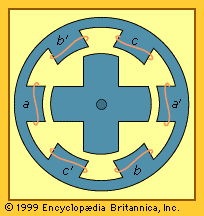
The basis of operation of the induction motor may be developed by first assuming that the stator windings are connected to a three-phase electric supply and that a set of three sinusoidal currents of the form shown in the flow in the stator windings. This shows the effect of these currents in producing a magnetic field across the air gap of the machine for six instants in a cycle. For simplicity, only the central conductor loop for each phase winding is shown. At the instant t1 in the , the current in phase a is maximum positive, while that in phases b and c is half that value negative. The result is a magnetic field with an approximately sinusoidal distribution around the air gap with a maximum outward value at the top and a maximum inward value at the bottom. At time t2 in the (i.e., one-sixth of a cycle later), the current in phase c is maximum negative, while that in both phase b and phase a is half value positive. The result, as shown for t2 in the , is again a sinusoidally distributed magnetic field but rotated 60° counterclockwise. Examination of the current distribution for t3, t4, t5, and t6 shows that the magnetic field continues to rotate as time progresses. The field completes one revolution in one cycle of the stator currents. Thus, the combined effect of three equal sinusoidal currents, uniformly displaced in time and flowing in three stator windings uniformly displaced in angular position, is to produce a rotating magnetic field with a constant magnitude and a mechanical angular velocity that depends on the frequency of the electric supply.
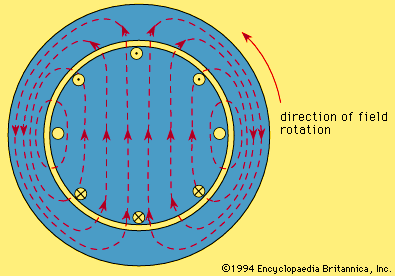
The rotational motion of the magnetic field with respect to the rotor conductors causes a voltage to be induced in each, proportional to the magnitude and the velocity of the field relative to the conductors. Since the rotor conductors are short-circuited together at each end, the effect will be to cause currents to flow in these conductors. In the simplest mode of operation, these currents will be about equal to the induced voltage divided by the conductor resistance. The pattern of rotor currents for the instant t1 of the is shown in this . The currents are seen to be approximately sinusoidally distributed around the rotor periphery and to be located so as to produce a counterclockwise torque on the rotor (i.e., a torque in the same direction as the field rotation). This torque acts to accelerate the rotor and to rotate the mechanical load. As the rotational speed of the rotor increases, its speed relative to that of the rotating field decreases. Thus, the induced voltage is reduced, leading to a proportional reduction in rotor conductor current and in torque. The rotor speed reaches a steady value when the torque produced by the rotor currents equals the torque required at that speed by the load with no excess torque available for accelerating the combined inertia of the load and the motor.
The mechanical output power must be provided by an electrical input power. The original stator currents shown in the are just sufficient to produce the rotating magnetic field. To maintain this rotating field in the presence of the rotor currents of the , it is necessary that the stator windings carry an additional component of sinusoidal current of such a magnitude and phase as to cancel the effect of the magnetic field that would otherwise be produced by the rotor currents in the . The total stator current in each phase winding is then the sum of a sinusoidal component to produce the magnetic field and another sinusoid, leading the first by one-quarter of a cycle, or 90°, to provide the required electrical power. The second, or power, component of the current is in phase with the voltage applied to the stator, while the first, or magnetizing, component lags the applied voltage by a quarter cycle, or 90°. At rated load, this magnetizing component is usually in the range of 0.4 to 0.6 of the magnitude of power component.
A majority of three-phase induction motors operate with their stator windings connected directly to a three-phase electric supply of constant voltage and constant frequency. Typical supply voltages range from 230 volts line-to-line for motors of relatively low power (e.g., 0.5 to 50 kilowatts) to about 15 kilovolts line-to-line for high-power motors up to about 10 megawatts.
The trusted destination for professionals, college students, and lifelong learners.
SUBSCRIBE


Except for a small voltage drop in the resistance of the stator winding, the supply voltage is matched by the time rate of change of the magnetic flux in the stator of the machine. Thus, with a constant-frequency, constant-voltage supply, the magnitude of the rotating magnetic field is held constant, and the torque is roughly proportional to the power component of the supply current.
With the induction motor shown in the foregoing figures, the magnetic field rotates through one revolution for each cycle of the supply frequency. For a 60-hertz supply, the field speed is then 60 revolutions per second, or 3,600 per minute. The rotor speed is less than the speed of the field by an amount that is just enough to induce the required voltage in the rotor conductors to produce the rotor current needed for the load torque. At full load, the speed is typically 0.5 to 5 percent lower than the field speed (often called synchronous speed), with the higher percentage applying to smaller motors. This difference in speed is frequently referred to as the slip.
Other synchronous speeds can be obtained with a constant frequency supply by building a machine with a larger number of pairs of magnetic poles, as opposed to the two-pole construction of the . The possible values of magnetic-field speed in revolutions per minute are 120 f/p, where f is the frequency in hertz (cycles per second) and p is the number of poles (which must be an even number). A given iron frame can be wound for any one of several possible numbers of pole pairs by using coils that span an angle of approximately (360/p)°. The torque available from the machine frame will remain unchanged, since it is proportional to the product of the magnetic field and the allowable coil current. Thus, the power rating for the frame, being the product of torque and speed, will be roughly inversely proportional to the number of pole pairs. The most common synchronous speeds for 60-hertz motors are 1,800 and 1,200 revolutions per minute.