
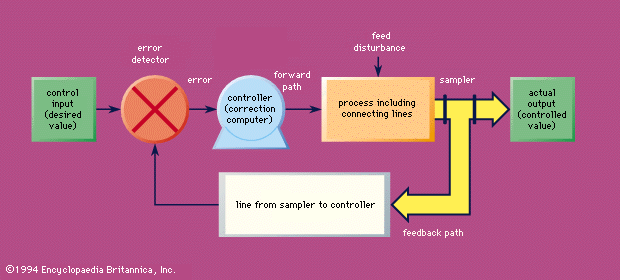


control system
-
What is a control system in technology?
A control system in technology ensures a variable quantity conforms to a set norm, maintaining constant values or varying them as needed. Operated electrically, mechanically, or via fluid pressure, these systems often integrate computers for efficient control.
Modern control systems in industrial plants use analog instruments, handling one input signal and delivering a single output correction, forming single-loop systems. Digital computers enhance control through supervisory, direct digital, and hierarchical methods, offering programmability for diverse tasks and easy adaptation to process changes. Automation, enhanced by feedback controls, improves manufacturing accuracy and testing. These systems consist of input, process, output, sensing elements, and controller devices.
6 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
What are the two main types of control systems?
The two main types of control systems are closed-loop control systems, also known as servomechanisms, and open-loop control systems. Closed-loop systems adjust the controlled quantity by using a motor that relies on a local power source, ensuring accuracy isn't compromised by signal distortion. The rate of energy supplied to the motor is determined by the difference between the actual and desired values. Open-loop control systems are feedforward systems, lacking self-correcting mechanisms.
2 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
How does a control system help manage machines or processes?
A control system ensures a variable quantity or a set of variable quantities conforms to a prescribed norm. It can maintain constant values or vary them as needed, using electricity, mechanics, fluid pressure, or a combination.
Modern control systems automate production lines using computerized production monitors, testing devices, and feedback-controlled production robots. Digital computers offer the advantage of being easily programmed to handle various tasks, and changes can be made without altering the physical equipment. Examples range from maintaining water levels in Roman aqueducts to regulating steam flow in James Watt's steam engine.
4 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
What is the difference between an open-loop and a closed-loop control system?
In a control system, an open-loop system lacks self-correcting capabilities, whereas a closed-loop system uses feedback to regulate itself.
Open-loop control systems are feedforward systems. Lacking feedback, they are unable to correct for disturbances or changes during operation.
Closed-loop control systems, also known as servomechanisms, maintain the desired value by measuring the controlled quantity and adjusting the system accordingly. These systems rely on feedback to minimize the difference between the actual and desired values.
2 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
Why is feedback important in a closed-loop control system?
Feedback is crucial in a closed-loop control system because it allows the system to self-correct and maintain the desired output.
Here's why it matters:
* Continuous Monitoring: Feedback involves sensing elements that constantly measure the output and compare it to the desired input or set point.
* Error Correction: The controller uses the difference between the actual and desired values to adjust the system's operation, reducing deviations and maintaining stability.
* Stability: By damping the system's response, feedback prevents overcorrection and hunting, ensuring smooth and accurate control.
* Enhanced Performance: Feedback control can modify a device's behavior to achieve the desired degree of fidelity.5 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
What are some examples of control systems used in everyday life or technology?
Control systems are used to maintain a desired value or to vary quantities in a specific way in many aspects of daily life and technology. These systems can be electrical, mechanical, or use fluid pressure, or a combination.
Examples include:
* Home appliances Many modern appliances, like microwave ovens, washing machines, and refrigerators, use microprocessors as computer controllers to automate functions such as timing, power levels, and cycle options.
* Automobiles Modern cars are equipped with microprocessors that manage engine control, fuel-air ratio, the clock, the radio, and cruise control.
* Aircraft Automatic pilots in aircraft manage flight without constant human intervention, controlling pitch, yaw, and roll. Modern systems can execute complex flight plans and even land the aircraft.
* Heating and cooling systems Atmosphere-control systems in buildings use thermostats to regulate temperature by controlling heat sources and distribution.
* Traffic control Traffic control systems use computers and communication devices to optimize traffic flow, providing routing advice and coordinating traffic signals.6 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles.
control system, means by which a variable quantity or set of variable quantities is made to conform to a prescribed norm. It either holds the values of the controlled quantities constant or causes them to vary in a prescribed way. A control system may be operated by electricity, by mechanical means, by fluid pressure (liquid or gas), or by a combination of means. When a computer is involved in the control circuit, it is usually more convenient to operate all of the control systems electrically, although intermixtures are fairly common.
Development of control systems.
Control systems are intimately related to the concept of automation (q.v.), but the two fundamental types of control systems, feedforward and feedback, have classic ancestry. The loom invented by Joseph Jacquard of France in 1801 is an early example of feedforward; a set of punched cards programmed the patterns woven by the loom; no information from the process was used to correct the machine’s operation. Similar feedforward control was incorporated in a number of machine tools invented in the 19th century, in which a cutting tool followed the shape of a model.
Feedback control, in which information from the process is used to correct a machine’s operation, has an even older history. Roman engineers maintained water levels for their aqueduct system by means of floating valves that opened and closed at appropriate levels. The Dutch windmill of the 17th century was kept facing the wind by the action of an auxiliary vane that moved the entire upper part of the mill. The most famous example from the Industrial Revolution is James Watt’s flyball governor of 1769, a device that regulated steam flow to a steam engine to maintain constant engine speed despite a changing load.



 " height="20" alt="HEW Logo">
The first theoretical analysis of a control system, which presented a differential-equation model of the Watt governor, was published by James Clerk Maxwell, the Scottish physicist, in the 19th century. Maxwell’s work was soon generalized and control theory developed by a number of contributions, including a notable study of the automatic steering system of the U.S. battleship “New Mexico,” published in 1922. The 1930s saw the development of electrical feedback in long-distance telephone amplifiers and of the general theory of the servomechanism, by which a small amount of power controls a very large amount and makes automatic corrections. The pneumatic controller, basic to the development of early automated systems in the chemical and petroleum industries, and the analogue computer followed. All of these developments formed the basis for elaboration of control-system theory and applications during World War II, such as anti-aircraft batteries and fire-control systems.
Most of the theoretical studies as well as the practical systems up to World War II were single-loop—i.e., they involved merely feedback from a single point and correction from a single point. In the 1950s the potential of multiple-loop systems came under investigation. In these systems feedback could be initiated at more than one point in a process and corrections made from more than one point. The introduction of analogue- and digital-computing equipment opened the way for much greater complexity in automatic-control theory, an advance since labelled “modern control” to distinguish it from the older, simpler, “classical control.”
Basic principles.
With few and relatively unimportant exceptions, all the modern control systems have two fundamental characteristics in common. These can be described as follows: (1) The value of the controlled quantity is varied by a motor (this word being used in a generalized sense), which draws its power from a local source rather than from an incoming signal. Thus there is available a large amount of power to effect necessary variations of the controlled quantity and to ensure that the operations of varying the controlled quantity do not load and distort the signals on which the accuracy of the control depends. (2) The rate at which energy is fed to the motor to effect variations in the value of the controlled quantity is determined more or less directly by some function of the difference between the actual and desired values of the controlled quantity. Thus, for example, in the case of a thermostatic heating system, the supply of fuel to the furnace is determined by whether the actual temperature is higher or lower than the desired temperature. A control system possessing these fundamental characteristics is called a closed-loop control system, or a servomechanism (see ). Open-loop control systems are feedforward systems.
The stability of a control system is determined to a large extent by its response to a suddenly applied signal, or transient. If such a signal causes the system to overcorrect itself, a phenomenon called hunting may occur in which the system first overcorrects itself in one direction and then overcorrects itself in the opposite direction. Because hunting is undesirable, measures are usually taken to correct it. The most common corrective measure is the addition of damping somewhere in the system. Damping slows down system response and avoids excessive overshoots or overcorrections. Damping can be in the form of electrical resistance in an electronic circuit, the application of a brake in a mechanical circuit, or forcing oil through a small orifice as in shock-absorber damping.
The trusted destination for professionals, college students, and lifelong learners.
SUBSCRIBE


Another method of ascertaining the stability of a control system is to determine its frequency response—i.e., its response to a continuously varying input signal at various frequencies. The output of the control system is then compared to the input with respect to amplitude and to phase—i.e., the degree with which the input and output signals are out of step. Frequency response can be either determined experimentally—especially in electrical systems—or calculated mathematically if the constants of the system are known. Mathematical calculations are particularly useful for systems that can be described by ordinary linear differential equations. Graphic shortcuts also help greatly in the study of system responses.
Several other techniques enter into the design of advanced control systems. Adaptive control is the capability of the system to modify its own operation to achieve the best possible mode of operation. A general definition of adaptive control implies that an adaptive system must be capable of performing the following functions: providing continuous information about the present state of the system or identifying the process; comparing present system performance to the desired or optimum performance and making a decision to change the system to achieve the defined optimum performance; and initiating a proper modification to drive the control system to the optimum. These three principles—identification, decision, and modification—are inherent in any adaptive system.
Dynamic-optimizing control requires the control system to operate in such a way that a specific performance criterion is satisfied. This criterion is usually formulated in such terms that the controlled system must move from the original to a new position in the minimum possible time or at minimum total cost.
Learning control implies that the control system contains sufficient computational ability so that it can develop representations of the mathematical model of the system being controlled and can modify its own operation to take advantage of this newly developed knowledge. Thus, the learning control system is a further development of the adaptive controller.
Multivariable-noninteracting control involves large systems in which the size of internal variables is dependent upon the values of other related variables of the process. Thus the single-loop techniques of classical control theory will not suffice. More sophisticated techniques must be used to develop appropriate control systems for such processes.