

vector analysis
-
What is a vector in mathematics?
In mathematics, a vector is a quantity possessing both magnitude and direction. Unlike scalars, which are described solely by their magnitude (like mass or temperature), vectors require both aspects to be fully defined. Common examples include velocity and acceleration.
Vectors can be visualized as directed line segments. They are fundamental in fields such as physics and engineering, where they are used to mathematically describe concepts like forces. Vector analysis, a branch of mathematics, deals with these quantities and their operations, including addition, subtraction, and different types of multiplication.
5 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
How are vectors represented and what do they show?
In mathematics, vectors are quantities possessing both magnitude and direction, often visualized as directed line segments. They are typically represented by boldface letters, such as v, with their magnitude indicated by |v| or v. Vectors are fundamental in fields like physics and mechanics to mathematically describe concepts such as velocity, force, and displacement. Vector analysis, a branch of mathematics, deals with these quantities and their operations, including addition, subtraction, and different types of multiplication, such as the dot product and cross product.
5 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
What is the difference between a vector and a scalar?
In vector analysis, the fundamental difference between a vector and a scalar lies in their properties. A scalar is a quantity fully described by its magnitude alone. Examples include mass, temperature, and time. Scalars are represented by real numbers and follow standard algebraic rules.
In contrast, a vector possesses both magnitude and direction. Quantities like velocity, force, and displacement are vectors. Vectors are often visualized as directed line segments, and their manipulation involves specific rules of vector algebra, including addition and multiplication by scalars.
6 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
How do you add or subtract vectors?
To add or subtract vectors, you can use graphical methods or algebraic component-wise operations. Graphically, vector addition can be visualized by placing the tail of the second vector at the head of the first; the resultant vector is drawn from the tail of the first to the head of the second. Alternatively, the parallelogram law can be used, where the sum is the diagonal of the parallelogram formed by the two vectors.
Vector subtraction is performed by adding the negative of the second vector, which means reversing its direction. Algebraically, if vectors are represented by their components (e.g., in a Cartesian coordinate system), addition and subtraction involve adding or subtracting the corresponding components. For example, if vector a = (a₁, a₂) and vector b = (b₁, b₂), then a + b = (a₁ + b₁, a₂ + b₂) and a - b = (a₁ - b₁, a₂ - b₂).
5 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
What is a dot product and how is it calculated?
The dot product, also known as the scalar product or inner product, is a fundamental operation in vector analysis. It takes two vectors and produces a single scalar value, which is a real number.
The dot product of two vectors, say a and b, is calculated by multiplying their magnitudes and the cosine of the angle between them:
[ \mathbf{a} \cdot \mathbf{b} = |\mathbf{a}| |\mathbf{b}| \cos(\theta) ]
where (|\mathbf{a}|) and (|\mathbf{b}|) are the magnitudes of vectors a and b, respectively, and (\theta) is the angle between them.This operation is particularly useful for determining the angle between two vectors. If the dot product of two non-zero vectors is zero, it signifies that the vectors are perpendicular.
4 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles. -
How does vector analysis help solve problems in physics and engineering?
Vector analysis is crucial in physics and engineering because it provides a mathematical framework to describe quantities with both magnitude and direction, such as force, velocity, and displacement. This allows for the formulation of physical laws in a way that is independent of specific coordinate systems. For instance, in fluid mechanics, the Navier-Stokes equations, which describe fluid flow, are expressed using vector notation. Vector analysis simplifies complex problems by enabling operations like vector addition and differentiation, which are essential for analyzing fields, motion, and interactions in various scientific and engineering disciplines.
8 Britannica SourcesCreated from Britannica articles using AI. AI can make mistakes, so verify using Britannica articles.
vector analysis, a branch of mathematics that deals with quantities that have both magnitude and direction. Some physical and geometric quantities, called scalars, can be fully defined by specifying their magnitude in suitable units of measure. Thus, mass can be expressed in grams, temperature in degrees on some scale, and time in seconds. Scalars can be represented graphically by points on some numerical scale such as a clock or thermometer. There also are quantities, called vectors, that require the specification of direction as well as magnitude. Velocity, force, and displacement are examples of vectors. A vector quantity can be represented graphically by a directed line segment, symbolized by an arrow pointing in the direction of the vector quantity, with the length of the segment representing the magnitude of the vector.
Vector algebra
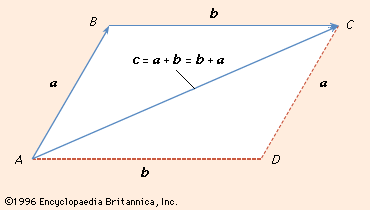
A prototype of a vector is a directed line segment AB (see ) that can be thought to represent the displacement of a particle from its initial position A to a new position B. To distinguish vectors from scalars it is customary to denote vectors by boldface letters. Thus the vector AB in can be denoted by a and its length (or magnitude) by |a|. In many problems the location of the initial point of a vector is immaterial, so that two vectors are regarded as equal if they have the same length and the same direction.
The equality of two vectors a and b is denoted by the usual symbolic notation a = b, and useful definitions of the elementary algebraic operations on vectors are suggested by geometry. Thus, if AB = a in represents a displacement of a particle from A to B and subsequently the particle is moved to a position C, so that BC = b, it is clear that the displacement from A to C can be accomplished by a single displacement AC = c. Thus, it is logical to write a + b = c. This construction of the sum, c, of a and b yields the same result as the parallelogram law in which the resultant c is given by the diagonal AC of the parallelogram constructed on vectors AB and AD as sides. Since the location of the initial point B of the vector BC = b is immaterial, it follows that BC = AD. shows that AD + DC = AC, so that the commutative law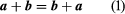 holds for vector addition. Also, it is easy to show that the associative law
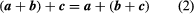 is valid, and hence the parentheses in (2) can be omitted without any ambiguities.



 " height="20" alt="HEW Logo">
If s is a scalar, sa or as is defined to be a vector whose length is |s||a| and whose direction is that of a when s is positive and opposite to that of a if s is negative. Thus, a and -a are vectors equal in magnitude but opposite in direction. The foregoing definitions and the well-known properties of scalar numbers (represented by s and t) show that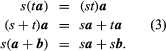
Inasmuch as the laws (1), (2), and (3) are identical with those encountered in ordinary algebra, it is quite proper to use familiar algebraic rules to solve systems of linear equations containing vectors. This fact makes it possible to deduce by purely algebraic means many theorems of synthetic Euclidean geometry that require complicated geometric constructions.
Products of vectors
The multiplication of vectors leads to two types of products, the dot product and the cross product.
The dot or scalar product of two vectors a and b, written a·b, is a real number |a||b| cos (a,b), where (a,b) denotes the angle between the directions of a and b. Geometrically,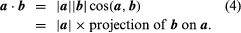
The trusted destination for professionals, college students, and lifelong learners.
SUBSCRIBE


If a and b are at right angles then a·b = 0, and if neither a nor b is a zero vector then the vanishing of the dot product shows the vectors to be perpendicular. If a = b then cos (a,b) = 1, and a·a = |a|2 gives the square of the length of a.
The associative, commutative, and distributive laws of elementary algebra are valid for the dot multiplication of vectors.
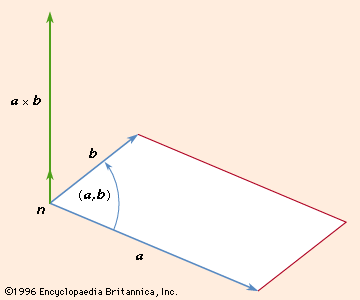
The cross or vector product of two vectors a and b, written a × b, is the vector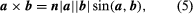 where n is a vector of unit length perpendicular to the plane of a and b and so directed that a right-handed screw rotated from a toward b will advance in the direction of n (see ). If a and b are parallel, a × b = 0. The magnitude of a × b can be represented by the area of the parallelogram having a and b as adjacent sides. Also, since rotation from b to a is opposite to that from a to b,

This shows that the cross product is not commutative, but the associative law (sa) × b = s(a × b) and the distributive law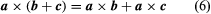 are valid for cross products.
Coordinate systems
Since empirical laws of physics do not depend on special or accidental choices of reference frames selected to represent physical relations and geometric configurations, vector analysis forms an ideal tool for the study of the physical universe. The introduction of a special reference frame or coordinate system establishes a correspondence between vectors and sets of numbers representing the components of vectors in that frame, and it induces definite rules of operation on these sets of numbers that follow from the rules for operations on the line segments.

If some particular set of three noncollinear vectors (termed base vectors) is selected, then any vector A can be expressed uniquely as the diagonal of the parallelepiped whose edges are the components of A in the directions of the base vectors. In common use is a set of three mutually orthogonal unit vectors (i.e., vectors of length 1) i, j, k directed along the axes of the familiar Cartesian reference frame (see ). In this system the expression takes the form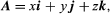 where x, y, and z are the projections of A upon the coordinate axes. When two vectors A1 and A2 are represented as
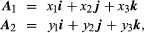 then the use of laws (3) yields for their sum
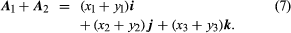
Thus, in a Cartesian frame, the sum of A1 and A2 is the vector determined by (x1 + y1, x2 + y2, x3 + y3). Also, the dot product can be written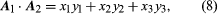 since
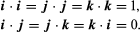
The use of law (6) yields for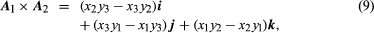 so that the cross product is the vector determined by the triple of numbers appearing as the coefficients of i, j, and k in (9).
If vectors are represented by 1 × 3 (or 3 × 1) matrices consisting of the components (x1,x2, x3) of the vectors, it is possible to rephrase formulas (7) through (9) in the language of matrices. Such rephrasing suggests a generalization of the concept of a vector to spaces of dimensionality higher than three. For example, the state of a gas generally depends on the pressure p, volume v, temperature T, and time t. A quadruple of numbers (p,v,T,t) cannot be represented by a point in a three-dimensional reference frame. But since geometric visualization plays no role in algebraic calculations, the figurative language of geometry can still be used by introducing a four-dimensional reference frame determined by the set of base vectors a1,a2,a3,a4 with components determined by the rows of the matrix
A vector x is then represented in the form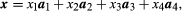 so that in a four-dimensional space, every vector is determined by the quadruple of the components (x1,x2,x3,x4).
Calculus of vectors
A particle moving in three-dimensional space can be located at each instant of time t by a position vector r drawn from some fixed reference point O. Since the position of the terminal point of r depends on time, r is a vector function of t. Its components in the directions of Cartesian axes, introduced at O, are the coefficients of i, j, and k in the representation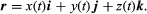
If these components are differentiable functions, the derivative of r with respect to t is defined by the formula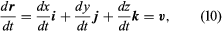 which represents the velocity v of the particle. The Cartesian components of v appear as coefficients of i, j, and k in (10). If these components are also differentiable, the acceleration a = dv/dt is obtained by differentiating (10):
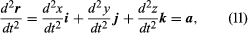
The rules for differentiating products of scalar functions remain valid for derivatives of the dot and cross products of vector functions, and suitable definitions of integrals of vector functions allow the construction of the calculus of vectors, which has become a basic analytic tool in physical sciences and technology.